
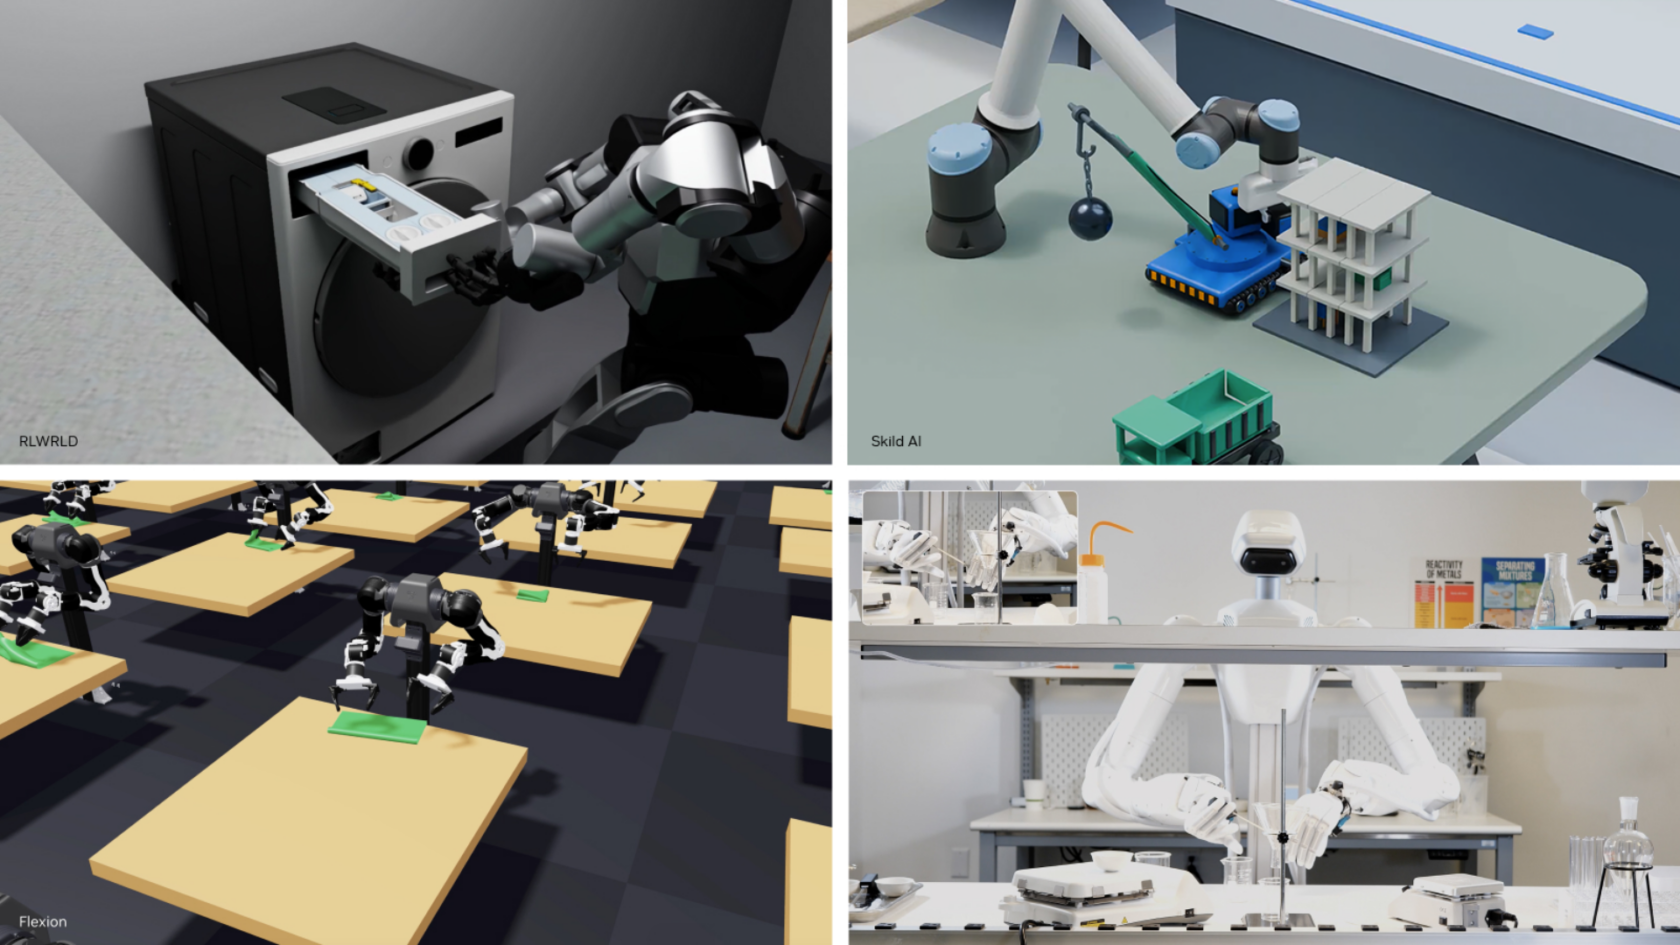
NVIDIA introduced new open robotics technologies at the Conference on Robot Learning in Austin, Texas, shifting simulation from locomotion toward delicate industrial manipulation tasks.
Simulation historically focused on teaching machines how to walk, roll, and hop across uneven terrain. Researchers at this week’s Conference on Robot Learning are pivoting toward tasks requiring a much finer touch, such as aligning gears, connecting cables, and assembling small components.
NVIDIA introduced GR00T 2 at the conference, an open frontier world action model built on NVIDIA Cosmos. The model trained on 100,000 hours of NVIDIA open-source human egocentric data to enable advanced dexterous manipulation.
GR00T 2 completed 40 of 50 evaluated tasks out of the box without requiring task-specific demonstrations. The model achieved a 71% average success rate across 50 tasks with a single demonstration, climbing to 95% success with five demonstrations.
Nexuni is testing the model for robotic laundry handling. Foxconn is applying GR00T 2 to factory automation for server manufacturing, and Siemens is evaluating the technology across industrial use cases.
Training capable robots requires massive parallel environments and physically accurate simulations to bridge the gap between virtual labs and the real world. NVIDIA released Isaac Lab 3.0 to provide that foundational simulation infrastructure.
The updated framework integrates tightly with Newton, an open-source physics engine capable of modeling deformable objects like cables and cloth. Isaac Lab 3.0 with Newton achieved up to 2.5 times the training throughput of Isaac Lab 2.3 using PhysX in vision-based dexterous manipulation benchmarks.
Skild AI announced the Scalable Throughput-optimized Engine for Embodied Learning, known as STEEL, built on Newton to accelerate robot training inside Isaac Lab. FieldAI utilizes Newton alongside Isaac Lab and Isaac Sim to validate robot policies for unstructured real-world environments.
AlphaNIST used Isaac Lab to train a single policy across all 20 tasks on the NIST Assembly Task Board. The system achieved a 98% training success rate while utilizing roughly 39 times less GPU time than separate per-task policies.
Evaluating robot performance reliably across changing conditions remains a critical challenge for industrial deployment. NVIDIA introduced Isaac Lab-Arena 0.4 at the conference to enable scaled policy evaluation across thousands of parallel variations.
DexBench, developed by RLWRLD in collaboration with NVIDIA, features 15 tasks across four scenes spanning retail, logistics, manufacturing, and hospitality. VABAR, the Variational Automation Benchmark for Agentic Robotics from UC Berkeley and NVIDIA, evaluates robots across six industrial tasks with standardized variations.
Agentic robotics integrates frontier agents to generate interpretable code for physical systems. UC Berkeley’s Graph-as-Policy framework uses these agents to connect individual skills into coordinated robot programs.
To me, agentic robotics is the most exciting technological development since the internet in 1995,
said Ken Goldberg, professor of robotics at UC Berkeley and a lead on the VABAR and Graph-as-Policy projects.
Ambi Robotics, Bosch Research, and Siemens are exploring Graph-as-Policy for agentic workflows across diverse industrial scenarios.
