
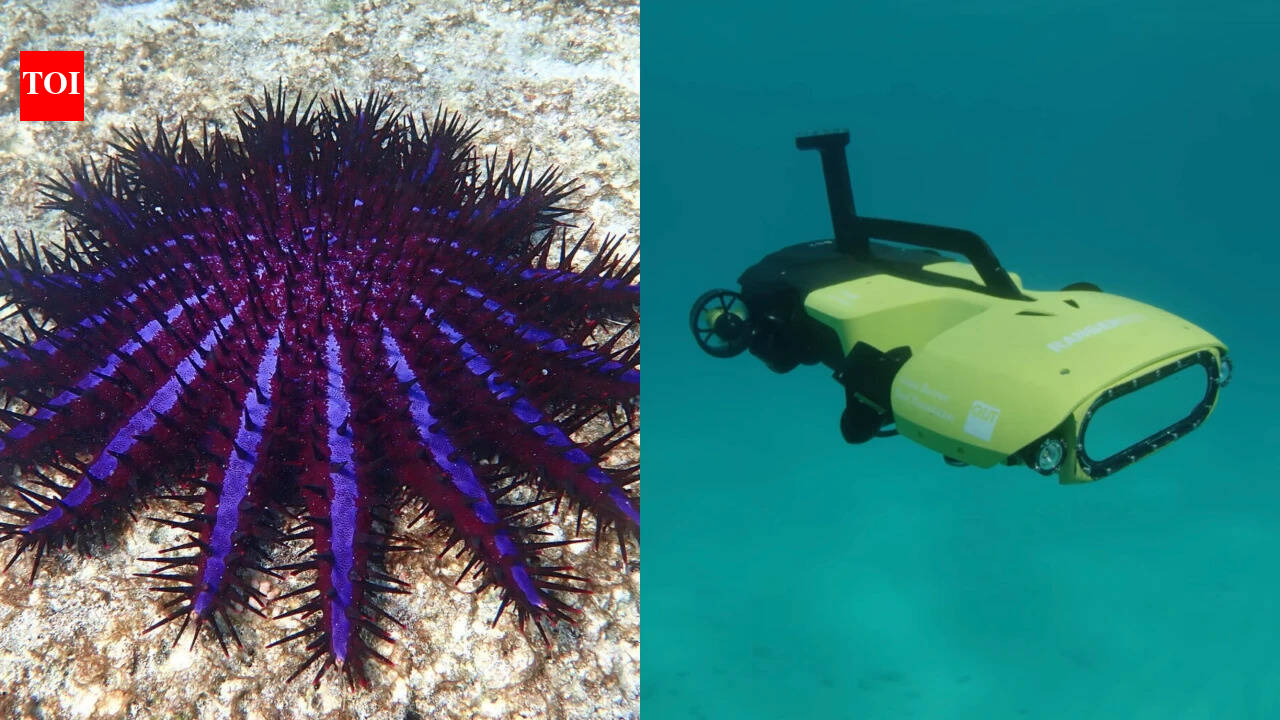
In 2018, RangerBot identified coral-eating crown-of-thorns starfish with 99.4% accuracy using a real-time computer vision system. Developed by Queensland University of Technology roboticists and funded via the 2016 Google Impact Challenge, the autonomous underwater vehicle delivers lethal bile salt injections to combat destructive outbreaks on the Great Barrier Reef.
From Manual Diver Culling to Autonomous Marine Robotics
External factors do not always threaten a coral reef. A native organism that actually plays a positive ecological role when present in typical numbers remains among the most persistent hazards to coral populations on the Great Barrier Reef. In modest quantities, the crown-of-thorns starfish (Acanthaster planci) aids slower-growing corals in establishing themselves by feeding on fast-growing coral species. Outbreaks occur when these populations surge, a phenomenon potentially driven by shifting ocean currents, reduced natural predation, an abundance of living coral, and excess nutrients. Researchers developed robotic systems on the premise that automated detection and culling could help supplement traditional diver-based control methods.
Parts of the Great Barrier Reef have frequently been devastated by crown-of-thorns surges, which researchers calculate account for a major portion of all coral depletion recorded across the reef over the past few decades. The traditional eradication approach—where human divers manually inject every single starfish with a lethal compound—proves effective yet sluggish and physically demanding, permitting crews to treat only a tiny fraction of the vast reef expanse within any given year.
Queensland University of Technology roboticists had been working on an automated replacement since the early 2000s. Their initial model could spot the starfish with a success rate of roughly sixty-five per cent, falling far short of the reliability required for independent operation.
Engineering RangerBot: Overcoming Vision and Navigation Hurdles
Following the 2016 Google Impact Challenge and nearly two years dedicated to research, engineering, and testing, QUT and its collaborators ultimately introduced RangerBot, a budget-friendly autonomous underwater vehicle presented to the public in 2018. Unlike older designs that relied on costly acoustic hardware and required constant manual steering by a human operator, RangerBot operates independently without being tethered to a watercraft. It roams freely on its own, using an onboard vision system.
An interim prototype known as COTSbot—named after the scientific acronym for the crown-of-thorns starfish—successfully demonstrated the foundational identification and injection mechanism back in 2015, though it still depended on a physical cable and constant supervision throughout missions. That achievement paved the way for RangerBot, which incorporates multiple thrusters for multidirectional movement and was built as a smaller, more economical alternative to earlier systems.
The principal engineering challenge of the project involved designing the machine to dependably differentiate crown-of-thorns starfish from all other underwater elements, which included several harmless starfish lookalikes. QUT stated that during trials, RangerBot’s real-time computer-vision system successfully spotted crown-of-thorns starfish with an accuracy rate of 99.4 per cent.
Targeted Eradication and Expansion Into Wider Reef Restoration
That high level of precision mattered greatly, as the machine’s subsequent action was final. Upon verifying a sighting, RangerBot administers a solitary dose of bile salts—a naturally derived compound formulated by James Cook University scientists—that specifically destroys crown-of-thorns starfish while leaving neighboring fish, corals, and other marine life completely unharmed. In numerous instances, a single dose proves sufficient to eliminate the targeted pest, improving upon legacy control methods that occasionally demanded multiple treatments for a single organism.
Rather than stemming from a conventional research grant, the machine originated from a popular public vote. The Great Barrier Reef Foundation secured victory in the 2016 Google Impact Challenge—backed by hundreds of thousands of public votes—which supplied the financial backing that enabled QUT roboticists to spend the subsequent two years perfecting the device prior to its 2018 debut at the Reef HQ Aquarium in Townsville.
Since its public introduction in 2018, the RangerBot framework has also been reconfigured for broader marine conservation and monitoring duties, encompassing water-testing operations and the distribution of coral larvae to harmed reef sectors, activities highlighted in QUT’s ongoing marine studies program. Furthermore, QUT re-engineered the hardware in 2018 to create LarvalBot for dispersing lab-grown coral babies across degraded marine habitats, achieving a scale of ecological rehabilitation that manual divers working alone could never accomplish.
The technology does not replace the divers, biologists, and reef managers who carry out much of the on-the-ground conservation work across the Great Barrier Reef. Because RangerBot can remain submerged for nearly triple the duration of a human diver during a single immersion, it manages to survey far greater expanses in one outing than any individual constrained by a limited oxygen supply could manage.
