
As autonomous systems scale from isolated warehouses to complex urban environments, developers are deploying frontier AI agents alongside NVIDIA Omniverse libraries to autonomously assemble, test, and refine physics-based simulation environments. This methodology allows engineers to move from raw text prompts to fully functional simulation pipelines—validating everything from robotic hardware constraints to multi-sensor autonomous vehicle frameworks.
Building Humanoid Warehouse Simulators Through Natural Language
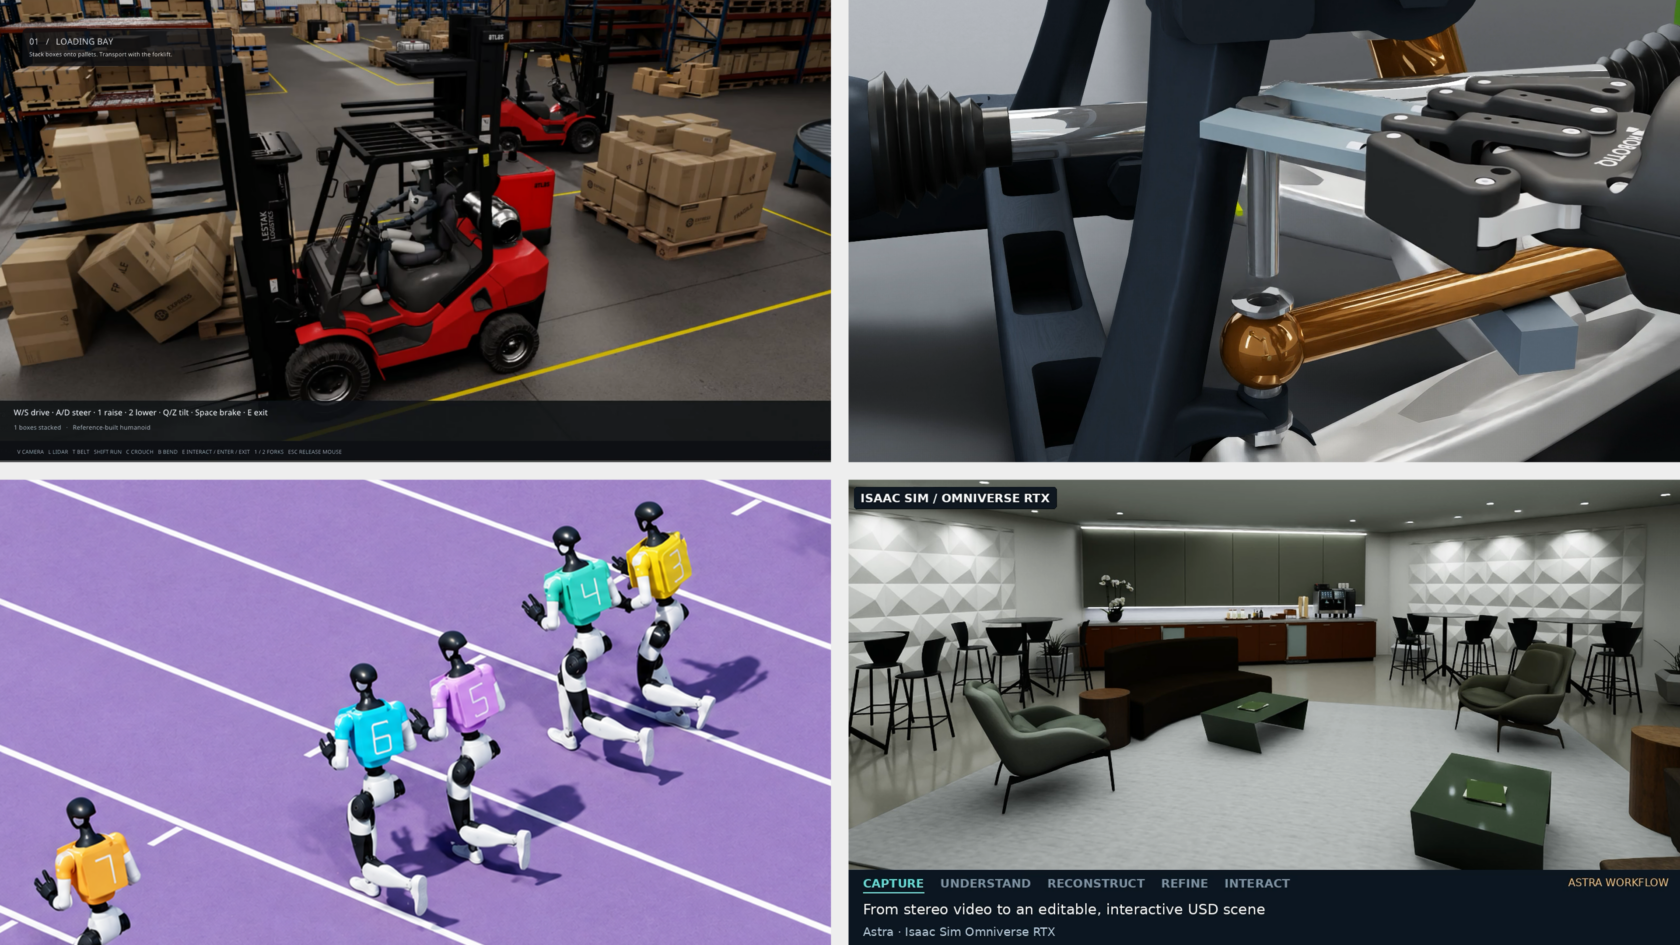
Simulating bipedal robots in logistics environments requires bridging high-level task behaviors with low-level physics engines. Frank DeLise, Omniverse product manager at NVIDIA, utilized the GPT-6 Astra model to transform a SimReady warehouse asset pack and a humanoid robot into an interactive simulation environment complete with first- and third-person perspectives.
DeLise instructed Astra to bind specific NVIDIA Omniverse libraries together. The workflow integrated ovphysx for physics, ovstage for scene updates, ovrtx for rendering, and ovui for the user interface layer. By combining these modular components with foundational SimReady assets (simready-foundation), the AI agent generated the requisite animation and application glue-code to orchestrate the entire interactive setup.
Connecting Autonomous Driving Workflows Along Market Street
In autonomous vehicle testing, altering a single sensor placement or lighting condition can drastically skew downstream perception models. Doyub Kim, a manager on the simulation technology team at NVIDIA, tasked Astra with building “Zero to Alpamayo”—a reusable simulation environment modeled after San Francisco’s Market Street.
Kim directed the agent to map the development pipeline sequentially, connecting asset generation, traffic, RTX sensor simulation, and Alpamayo driving in stages, checking each integration. In a related experiment utilizing Cosmos3-Nano, Kim adjusted environmental parameters like weather and illumination across recorded simulation feeds to evaluate how the autonomous driving stack reacts to identical inputs under divergent physical states.
Measuring Sensor Discrepancies to Build High-Fidelity Digital Twins
Validating whether virtual sensors match physical hardware remains a critical engineering hurdle for autonomous robotics. Ashley Reid, who works on RTX sensor validation at NVIDIA, guided Astra and Claude Fable 5 agents through a three-day iterative workflow to measure data discrepancies between simulated outputs and real-world captures, as blogs.nvidia.com documented.
The agents compared ovrtx camera feeds and raw LiDAR point clouds directly against recorded logs, automatically modifying OpenUSD scenes to correct missing geometry, material properties, and object placement. Scene acceptance relied entirely on quantitative KPI metrics derived from camera and LiDAR sensor deltas.
An NVIDIA sensor-validation engineer guided agents for about three days to compare simulated camera and LiDAR output against recorded data, then create or fix digital twins until the metrics passed. That is the right shape for agent work: a clear target, a numeric acceptance test, and a human deciding when it is good enough.
— deskofai.com
Putting Unitree G1 Humanoids Through the Robo Olympics
Physical constraints present steep algorithmic barriers when teaching humanoid robots dynamic maneuvers. Tae Kim, who leads NVIDIA Omniverse engineering and product, used sports reference footage and natural-language prompts to build the “Robo Olympics,” testing simulated Unitree G1 humanoids executing athletic movements.
Astra constructed custom motor controllers and refined them via iterative physics trials. The Newton Physics Engine simulated behavior, the open-source NVIDIA Warp framework accelerated calculations, and ovrtx handled real-time rendering. During hurdle-clearance experiments, the simulated biped successfully cleared a single hurdle in 64 out of 100 trials, supplying feedback for improving the robot’s timing and control.
However, deskofai.com notes a vital reality check regarding these outcomes: the trials are a reminder that agent-built controllers still fail a lot, even in a clean virtual world. Furthermore, deskofai.com highlights that every featured project originates from NVIDIA staff using NVIDIA libraries, leaving open questions regarding external developer cost efficiency and agent failure rates at scale.
Streaming the International Space Station Directly Into Web Browsers
Assembling multi-gigabyte 3D assets, live telemetry streams, and responsive web user interfaces typically demands extensive manual front-end development. Nic Johns, engineering director at NVIDIA, prompted Astra to assemble NASA datasets into an interactive OpenUSD model of the International Space Station with live operational telemetry, executing the build from a single natural-language instruction.
Reconstructing Real-World Rooms Into Editable USD Testing Environments
Transforming raw stereo camera captures into responsive simulation assets requires automated geometry cleaning and physical property assignment. Chirag Majithia from the Isaac engineering applications team directed Astra to convert stereo captures into editable OpenUSD studio scenes.
The reconstruction pipeline integrated PyCuSFM, FoundationStereo, and nvblox.
