
NVIDIA released Isaac ROS 5.0 today at the ROSCon conference in Toronto, Canada, introducing GPU-accelerated software packages and agentic workflows designed to help developers and AI agents build, customize, and deploy physical AI robotics applications faster using the open-source Robot Operating System (ROS) framework.
Modern robotics requires systems that can perceive, reason, and act within unpredictable real-world environments. Meeting this demand requires scalable computing and efficient pipelines that bridge open-source architecture with hardware acceleration. The latest iteration of Isaac ROS bridges this gap by bringing production-ready libraries and physical AI models directly to the roughly 1.3 million global ROS users.
Bringing Autonomous Agents Into Robotics Development
Software development workflows are shifting as AI agents automate repetitive coding tasks and navigate complex codebases. Isaac ROS 5.0 introduces these capabilities to the robotics domain, supporting ROS Lyrical and Ubuntu 24.04. This provides developers with an immediate path to adopt the latest ROS platform while leveraging NVIDIA-accelerated computing for heavy workloads.
To streamline performance across different computing hardware, NVIDIA collaborated with the Open Source Robotics Alliance to contribute a standard data-handling interface to ROS Lyrical. This interface allows robotics software to operate efficiently across various hardware setups, with CUDA serving as a working example for GPU acceleration.
New NVIDIA Isaac skills for setup and manipulation supply reusable workflows that developers and AI agents can employ to complete engineering tasks. Furthermore, agent-ready documentation assists AI agents in interpreting Isaac ROS tools, translating developer intent into functional code rapidly.
Specific perception models have also received updates. A new FoundationStereo fine-tuning skill enables an AI agent to help adapt stereo perception models to specific cameras, environments, and sensor configurations. Meanwhile, FoundationPose—a foundation model for object pose estimation and tracking—now features an agent-ready inference library, allowing robots to perceive and track object position and orientation up to 5.5 times faster. A common pick-and-place workflow connecting detection, depth estimation, and pose output is now packaged as a standalone, agent-ready skill.
Expanding the Open Source Robotics Ecosystem
The broader robotics ecosystem is rapidly integrating these agentic development frameworks. AgenticROS, an open-source project sponsored by 3D perception technology firm RealSense, connects Isaac ROS with NVIDIA Nemotron open models and NVIDIA NemoClaw blueprints to let AI agents interact directly with ROS-based robots. RealSense is also optimizing its AI-native 3D stereo depth cameras, including the RealSense D585 Pro, alongside an open-source software development kit for Isaac ROS and the NVIDIA Jetson Thor edge AI platform.

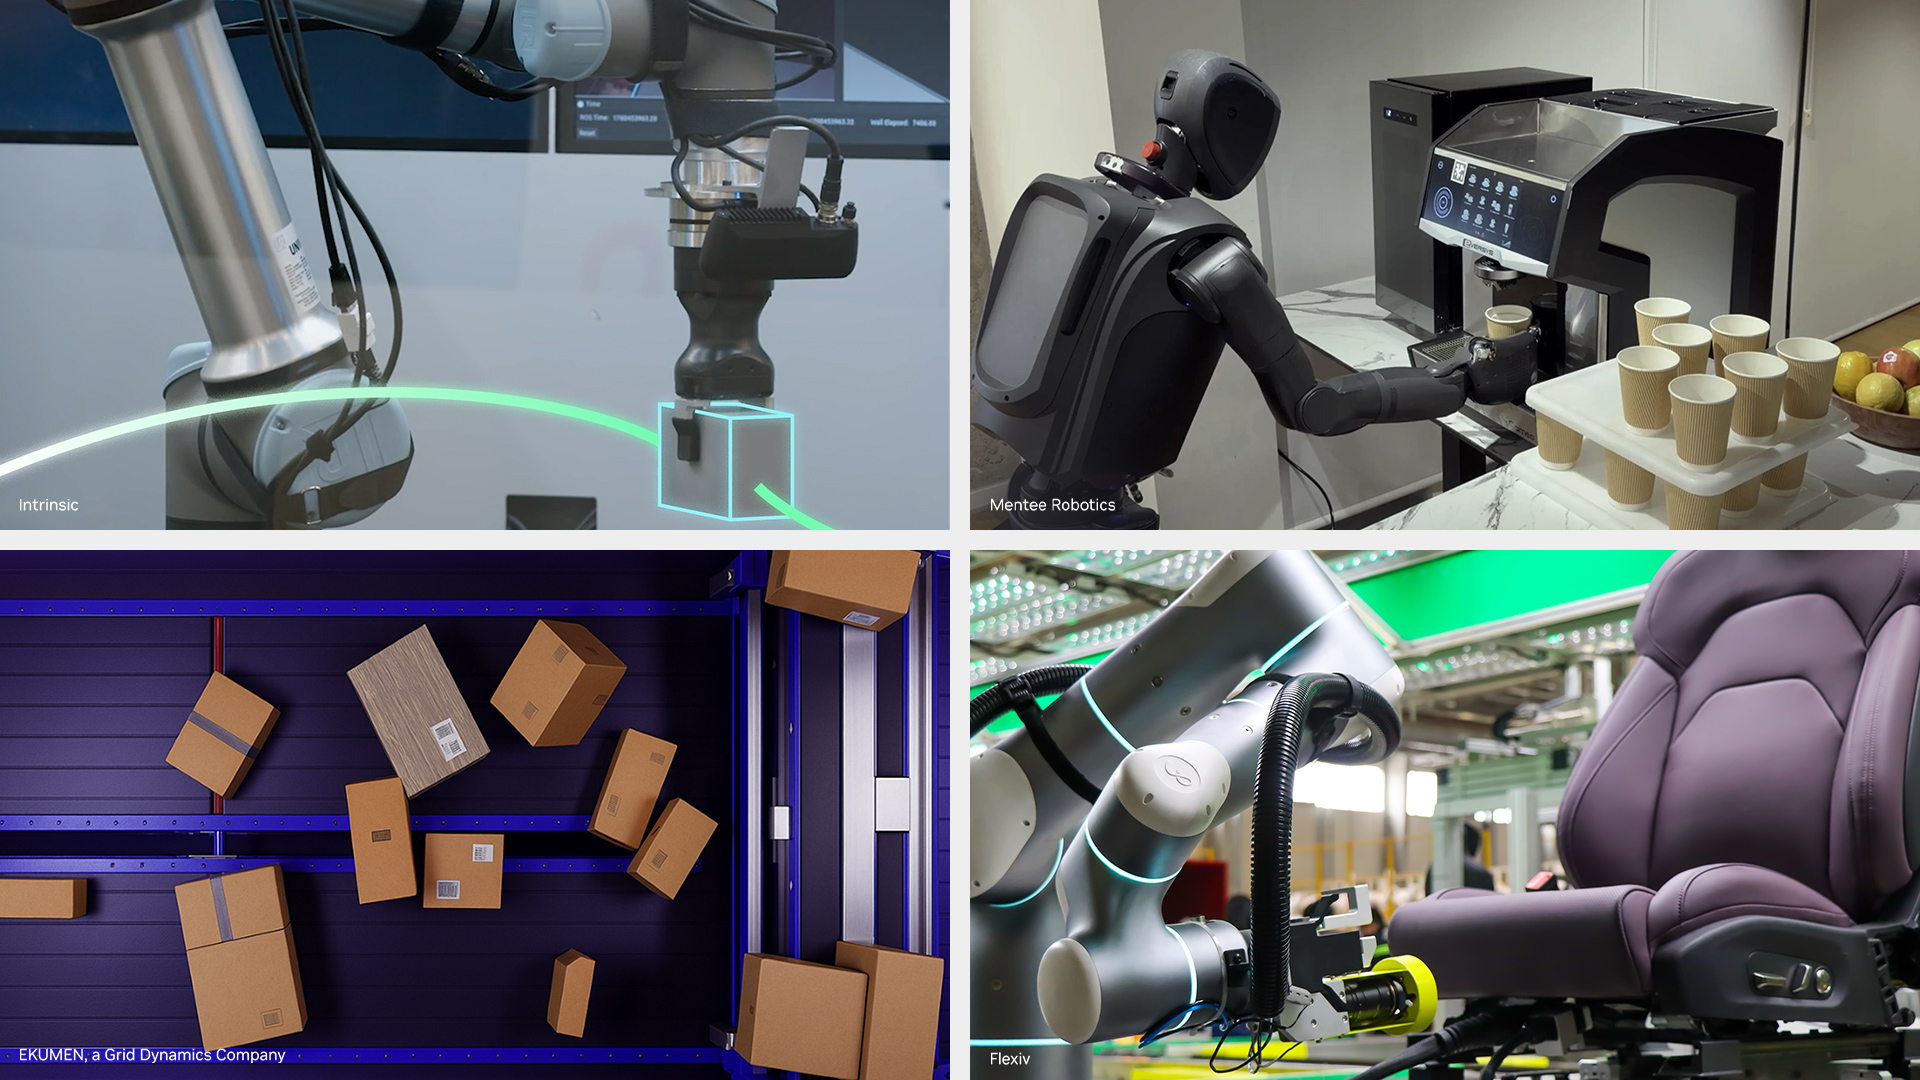
Industrial applications are leveraging these tools to reduce reliance on rigid physical fixtures. Intrinsic’s Open Machine Tending Solution—part of the newly released Intrinsic Core suite of preconfigured runtime services—includes built-in compatibility with NVIDIA FoundationPose for out-of-the-box object registration, tracking, and pose estimation. This configuration allows robots to dynamically handle parts in computer numerical control machine tending.
Additional ecosystem partners are utilizing the software stack to streamline deployment:
- Seeed Studio: Combining accelerated perception, spatial understanding, and motion planning on NVIDIA Jetson Thor via the reBot Arm platform.
- Magna: Pairing Isaac ROS with Isaac Sim hardware-in-the-loop testing for synchronized data collection and GR00T model deployment in manufacturing and mobility.
- Prefix.dev: Utilizing the Pixi package-management tool to create reproducible robot development environments that bring ROS and CUDA together.
- Foxglove: Integrating visualization and debugging tools throughout Isaac ROS tutorials to support 3D topics, nvblox meshes, and rosbags.
- Flexiv: Connecting Isaac ROS with the Rizon 4 adaptive robot for streamlined testing in Isaac Sim and deployment on physical welding arms.
- Ekumen: Deploying GPU-accelerated packages like isaac_ros_cumotion to map collision-free paths for warehouse arms in roughly 2 to 5 milliseconds within Nav2 stacks.
- Ouster: Integrating Stereolabs ZED stereo cameras with Isaac ROS for real-time object detection and mapping.
Scaling the Edge AI Stack on NVIDIA Jetson
Applications built with these tools ultimately execute on the robot hardware itself. NVIDIA Jetson provides a scalable computing platform for running physical AI at the edge, spanning entry-level devices like the Jetson Orin Nano up to high-performance Jetson Thor systems.
Humanoid and industrial robotics manufacturers are incorporating this stack directly into their hardware architectures:
- Mentee Robotics: Utilizing Isaac ROS as the perception and AI backbone for the MenteeBot humanoid, allowing the system to interpret visual data and execute learned behaviors in real time across Orin and Thor platforms.
- Universal Robots: Building Isaac ROS into its AI Accelerator software development kit to help integrators deploy perception and motion capabilities without building software from scratch.
- ROBOTIS: Integrating Isaac ROS into the AI Worker robot alongside TurtleBot3 development setups to execute vision-guided pick-and-place tasks via CuMotion.
- FieldAI: Running robot foundation models entirely on-edge without cloud connectivity by integrating Isaac ROS on Jetson devices.
- Noble Machines: Accelerating the development of general-purpose industrial robots using ready-to-use perception packages.
NVIDIA Isaac ROS 5.0 is available now as a free, open-source release, accessible to developers via GitHub.
