
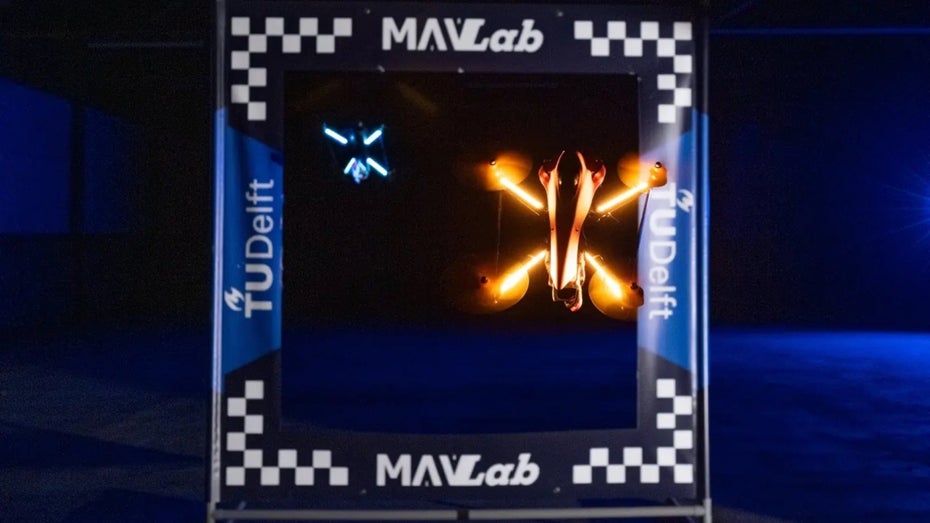
In a stunning upset at the Abu Dhabi Autonomous Drone Racing Competition, an autonomous system developed by Team MAVLab outmaneuved human world champion Yuki Hashimoto. Operating without GPS or external tracking, the Dutch AI platform relied on a single low-cost camera to move through a high-speed course at speeds reaching 100 kilometers per hour, t3n.de reported. The system, known as MonoRace, was presented in the journal Science Robotics around a year and a half after the event.
How MonoRace Navigates Without GPS
The system, known as MonoRace, bypasses the need for heavy compute clusters or redundant sensor suites. Instead, it pairs an eight-megapixel camera that costs roughly 30 euros, provided as the event’s drone model by the competition organizers, with an inertial measurement unit and a flight controller, feeding data into an Nvidia Jetson Orin nanocomputer.
Processing power is conserved by cropping input frames to a tight 384 by 384 pixel window. Reinforcement learning in simulation taught the neural network how to handle physical drag, motion blur, and sensor noise before ever touching a physical airframe. Anstatt die Drohne mit immer leistungsfähigeren Sensoren und Computern auszustatten, wollten wir herausfinden, wie viel Intelligenz wir aus sehr begrenzten Ressourcen herausholen können,
explained researcher Christophe De Wagter.
The flying with very high speed and only one camera is a challenge, because the images are blurry and distorted and the AI system has very little time to precisely determine the drone’s position,
explained Stavrow Bahnam of TU Delft, the study’s lead author, as detailed in Science Robotics.
Executing 500 Control Commands Per Second
Rather than mapping out an entire pre-determined track geometry, MonoRace continuously recalculates the positions of the next two gates in real time. The neural network strips the background from the image feed, reducing the visual data to high-contrast binary masks that isolate the frame edges.
Algorithms identify the exact intersection points of these gates. The flight controller then receives up to 500 precise adjustment commands every single second.
This extreme optimization allowed the TU Delft quadrotor to surpass both elite human pilots and competing autonomous entries during the 2025 event in the Emirates. The research team intends for these lightweight control methods to translate into broader applications for resource-constrained robotics.
