

NVIDIA has unveiled a sophisticated robotic training workflow, detailed by NVIDIA Developer, that employs autonomous AI agents to teach the Microduck robot complex locomotion and how to avoid obstacles within a high-fidelity simulation. By integrating agents like Hermes, Nemotron, and Astra, the system automates the transition from conceptual planning to physical policy deployment.
Microduck robot uses sim-to-real methodology to walk
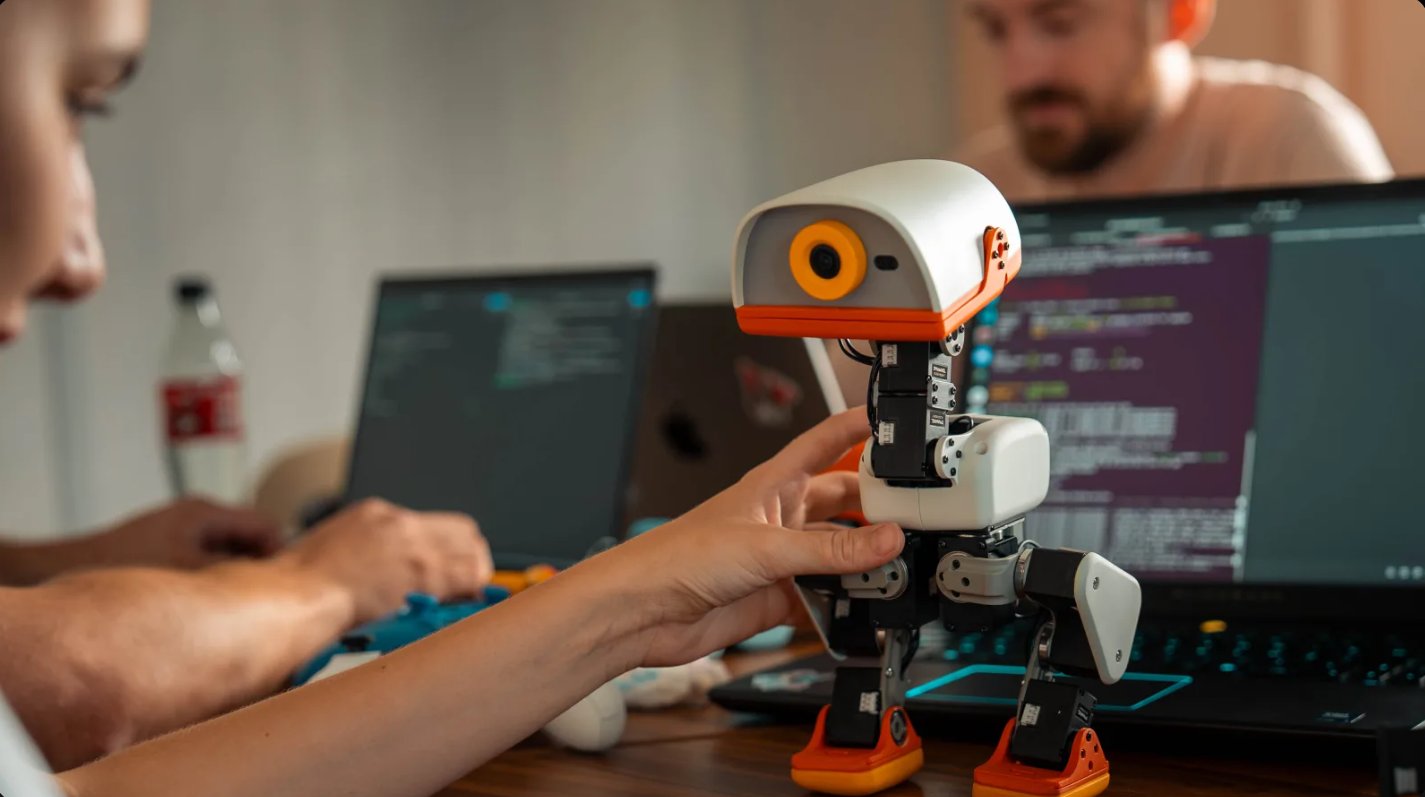
The Microduck, a 25-centimeter-tall, 800-gram open-source robot developed by Pollen Robotics and Hugging Face, serves as the primary subject for this training regimen. Priced at an introductory $399, the robot features 15 motors, a camera, and dual inertial measurement units. According to TechRepublic, the robot’s ability to walk, crouch, and recover from falls is the result of a “sim-to-real” methodology where policies are refined in virtual space before being ported to hardware.
Autonomous Planning with Hermes and Nemotron
The workflow begins on the RTX Spark local development hub, where the Hermes and NVIDIA Nemotron 3.5 Bolt agents ingest high-level user prompts to generate structured project plans. These agents define the obstacle course layout, identify necessary assets, and establish the technical constraints of the environment. This planning phase ensures that the simulated course—complete with ramps and uneven terrain—is optimized for reinforcement learning (RL) before any physical assets are modeled. Daily.dev reports that this agent-driven orchestration significantly reduces the manual overhead typically associated with setting up complex robotics simulations.
Astra agent and Isaac Lab scale 3D simulation
Once the plan is finalized, the Astra agent takes over, utilizing FreeCAD and Blender to construct 3D assets. For developers seeking to accelerate this stage, the SimReady Central Library offers over 2,000 pre-built, OpenUSD-compliant assets. The actual training occurs within NVIDIA Isaac Lab, which uses the Newton physics engine to model real-world physical behaviors. To achieve stable walking policies, the training runs are massively parallelized. As documented by Daily.dev, a single adaptation run for ramp traversal utilized 4,096 parallel environments on an NVIDIA RTX PRO 6000 Blackwell Workstation Edition GPU. This scale allows the robot to encounter millions of simulated steps per second, significantly shortening the time required to develop adaptive movement strategies.
Bridging the Sim-to-Real Gap
The final stage of the workflow focuses on minimizing the performance delta between the simulation and the physical robot. NVIDIA employs Better Actuator Models (BAM) to replicate servo response characteristics and uses domain randomization to force the policy to handle unpredictable variables like sensor noise and varying ground friction. The resulting policy is exported and loaded onto the physical Microduck. While the initial preorder deliveries for the hardware are targeted for before Christmas 2026, the software tools for this training pipeline are currently available for developers to begin experimenting with their own locomotion policies.
Blackwell GPUs and AI agents accelerate physical AI training
- Training Efficiency: The use of 4,096 parallel environments on Blackwell-class GPUs allows for rapid policy iteration.
- Agent-Driven Workflow: AI agents automate the tedious parts of environment construction, from asset generation in Blender to project planning.
- Hardware Context: The Microduck hardware is an open-source platform, positioning this workflow as a significant tool for researchers and students working on physical AI.
- Deployment Strategy: Domain randomization and BAM are critical for ensuring that virtual learning translates to stable movement on physical hardware.
With the Isaac Lab framework now open for broader use, the barrier to entry for complex robotics training has been lowered, provided users have access to high-performance local compute resources.
Tiny robots, big AI power! Nvidia CEO Jensen Huang showcased four Microduck robots at GTC Berlin, demonstrating how AI, simulation software and cloud computing can help robots learn physical movements.Developed by Hugging Face and Pollen Robotics, the open-source robots were… pic.twitter.com/uBjD3Tj7Yx
